MAM5-INUM - Commande optimale
TP 1 - Navigation problem (a.k.a. Zermelo-Markov-Dubins)
Special thanks: P. Negre & M. Sadak (Polytech Nice Sophia)
One considers a ship in a constant current, \(0 \leq w \lt 1\). The angle of the velocity (wrt. to the water) is controlled, leading to the following dynamics:
\[ \begin{array}{rcl} \dot{x}(t) &=& w+\cos\theta(t),\quad t \in [0,t_f]\\ \dot{y}(t) &=& \sin\theta(t),\\ \dot{\theta}(t) &=& u(t). \end{array} \]
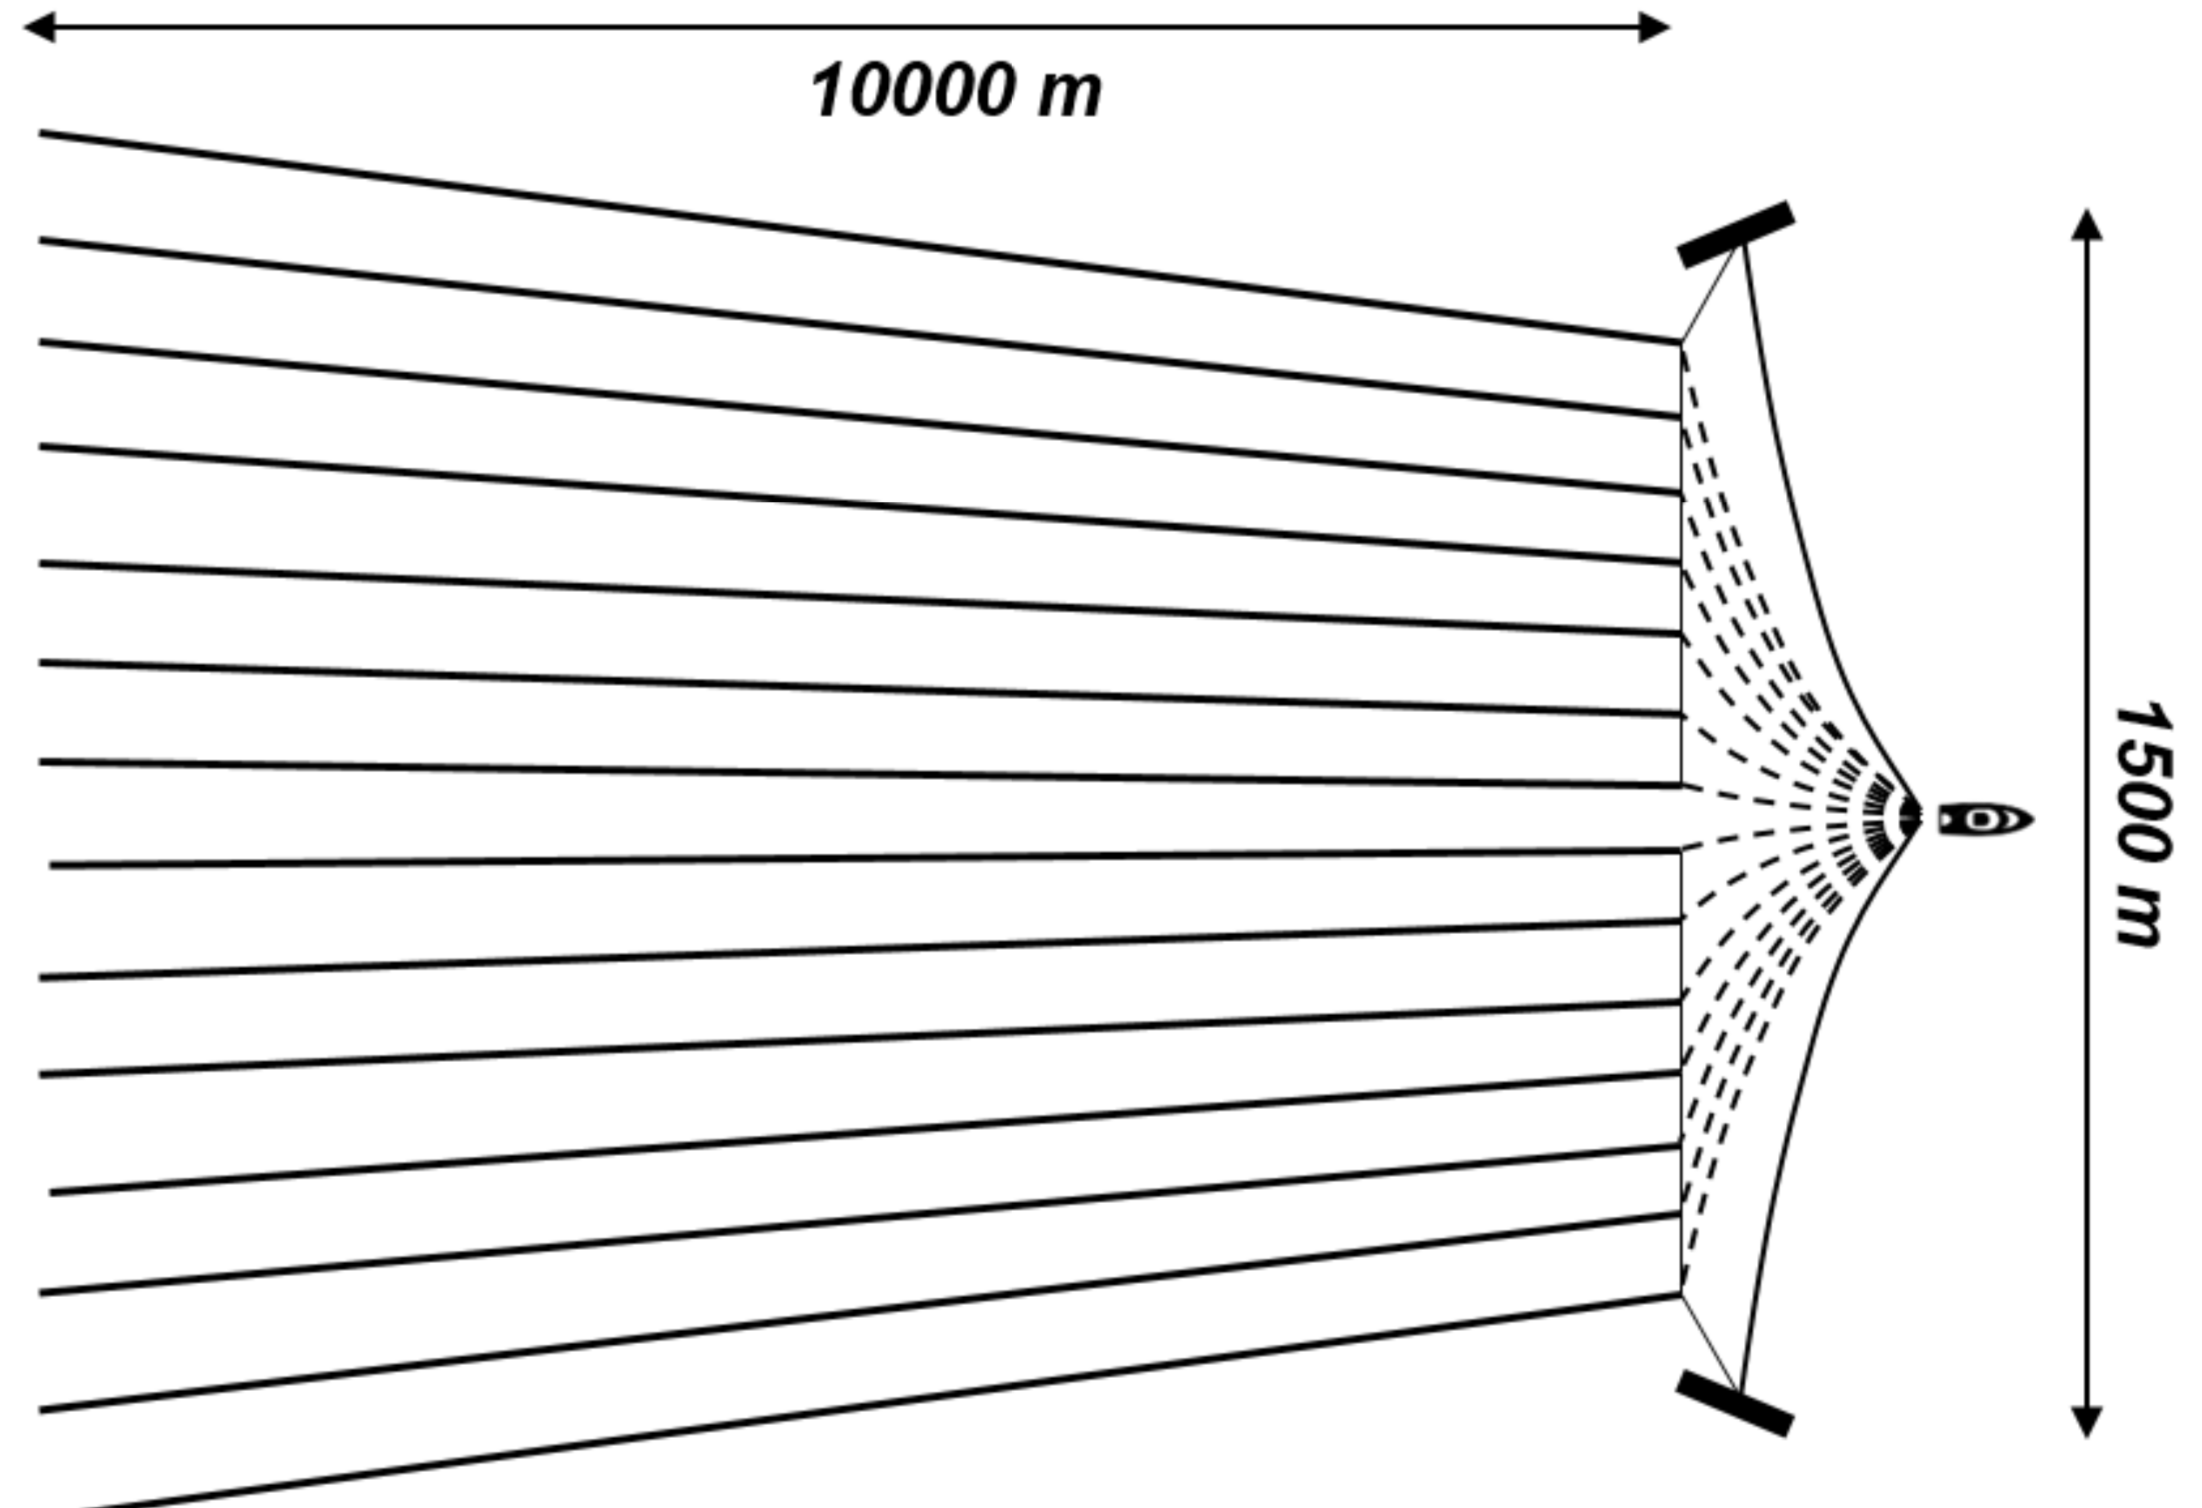
The turning rate (= curvature of turns) is limited, so \(|u(t)| \leq 1\). There boundary conditions at \(t=0\) and \(t=t_f\) on the position \((x,y)\) and on the angle \(\theta\) of the velocity in the water referential. The final time is to be minimised. The problem originates from a collaboration with the French company CGG that is interested in optimal maneuvers for very large ships doing marine prospection.
using OptimalControl
using NLPModelsIpopt
using Plots

# Parameters
w = 0.8
x0 = 0
y0 = 0
θ0 = π/7
xf = 4
yf = 7
θf =-π/2
N = 100

ocp = @def begin
    tf ∈ R, variable
    t ∈ [0, tf], time
    X = (x, y, θ) ∈ R³, state
    u ∈ R, control

    X(0)  == [x0, y0, θ0]
    X(tf) == [xf, yf, θf]

    -1 ≤ u(t) ≤ 1

    ∂(x)(t) == w + cos(θ(t))
    ∂(y)(t) == sin(θ(t))
    ∂(θ)(t) == u(t)

    tf → min
end
# Solves for the control and state
println("Solving...")
N = 200
sol = solve(ocp; disc_method=:euler, grid_size=N)
plot(sol)